Approach Move Close


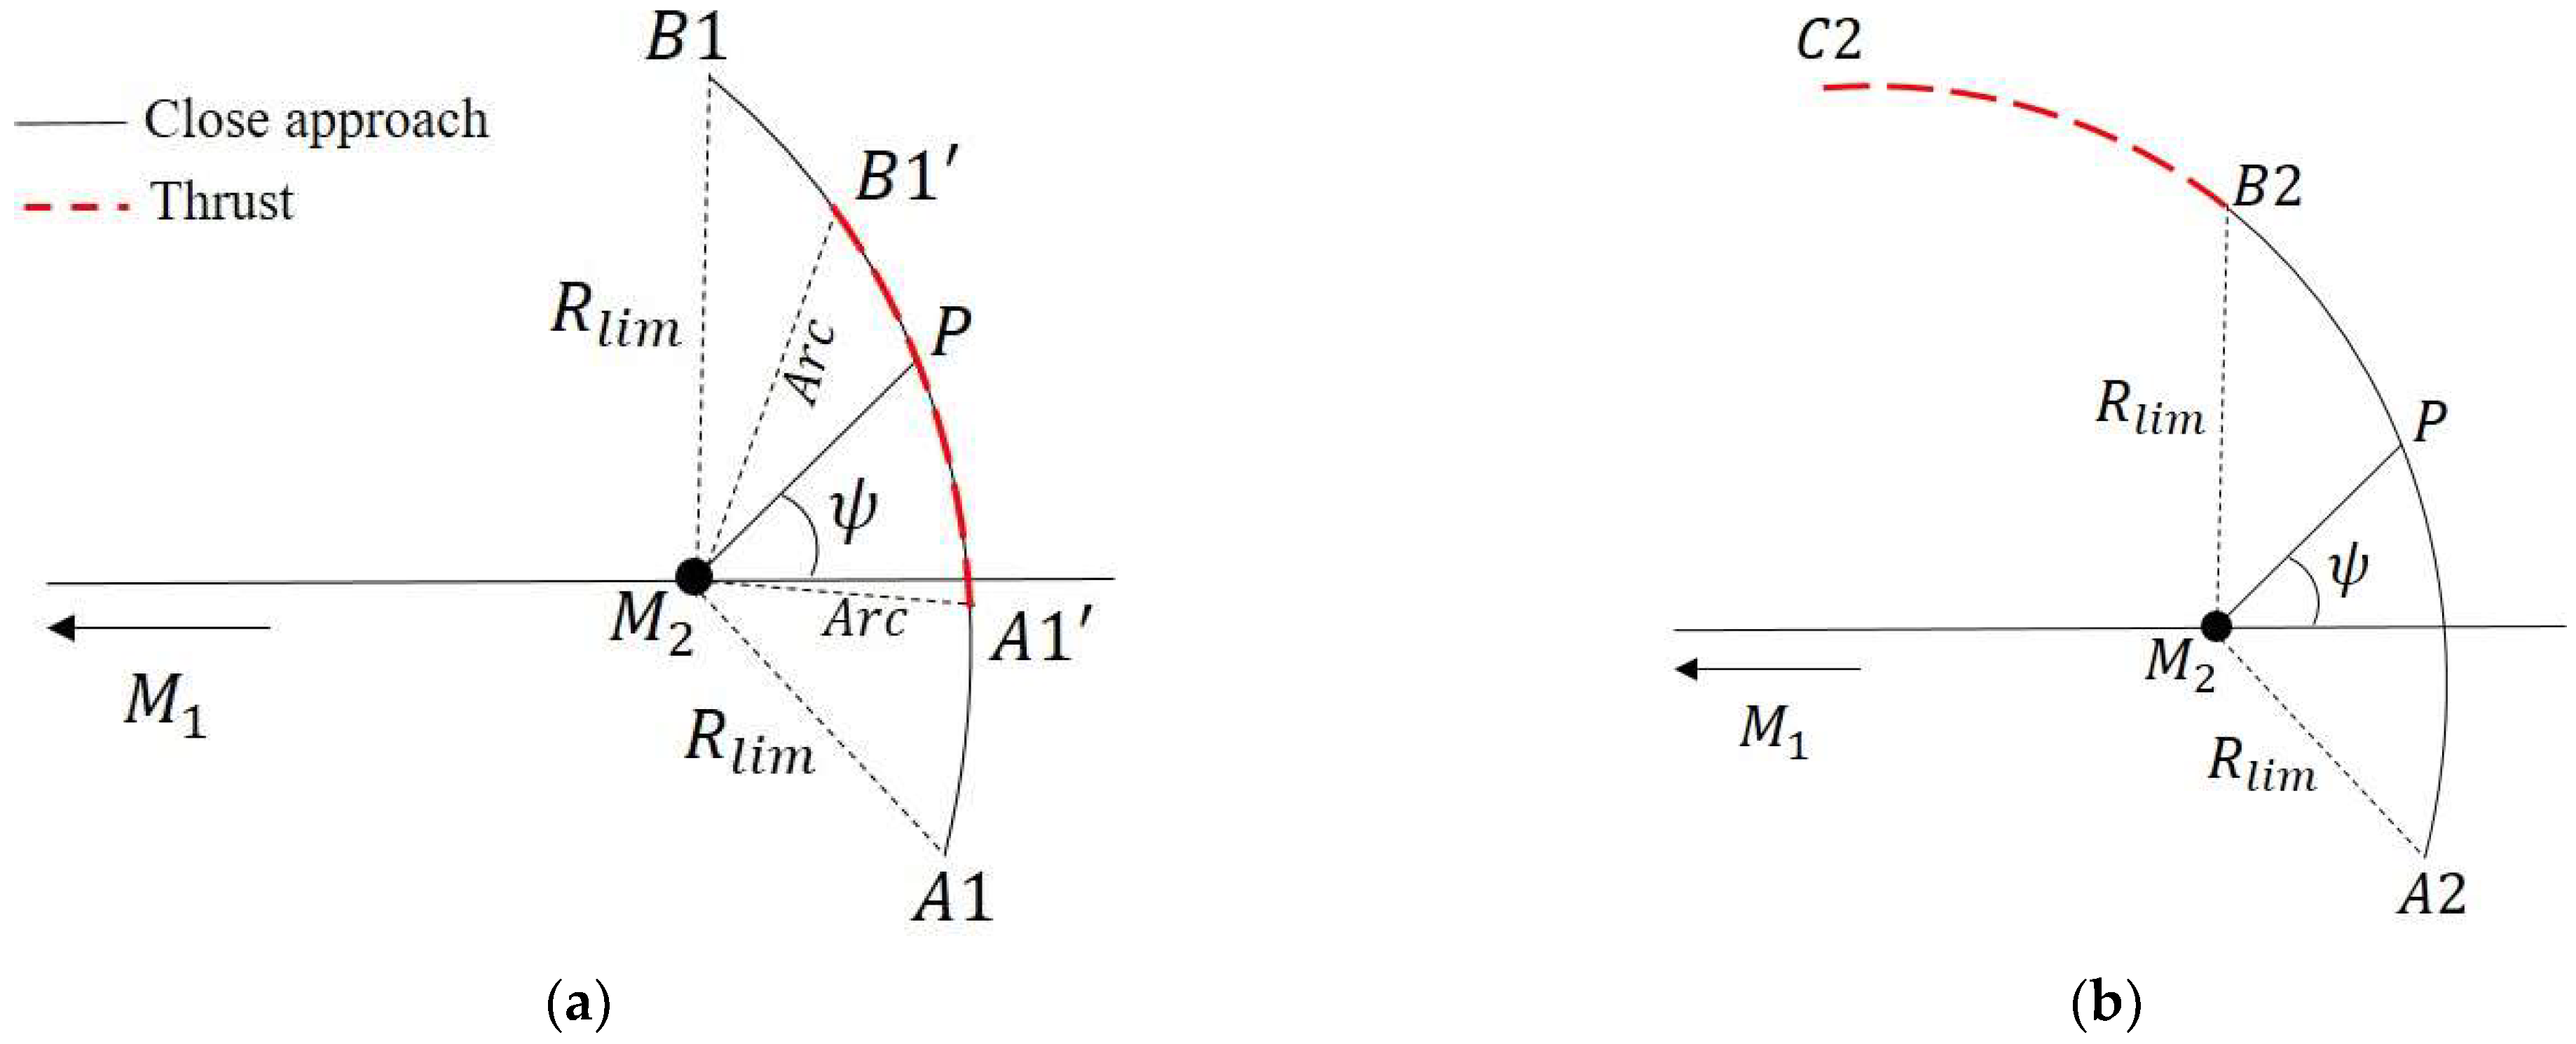
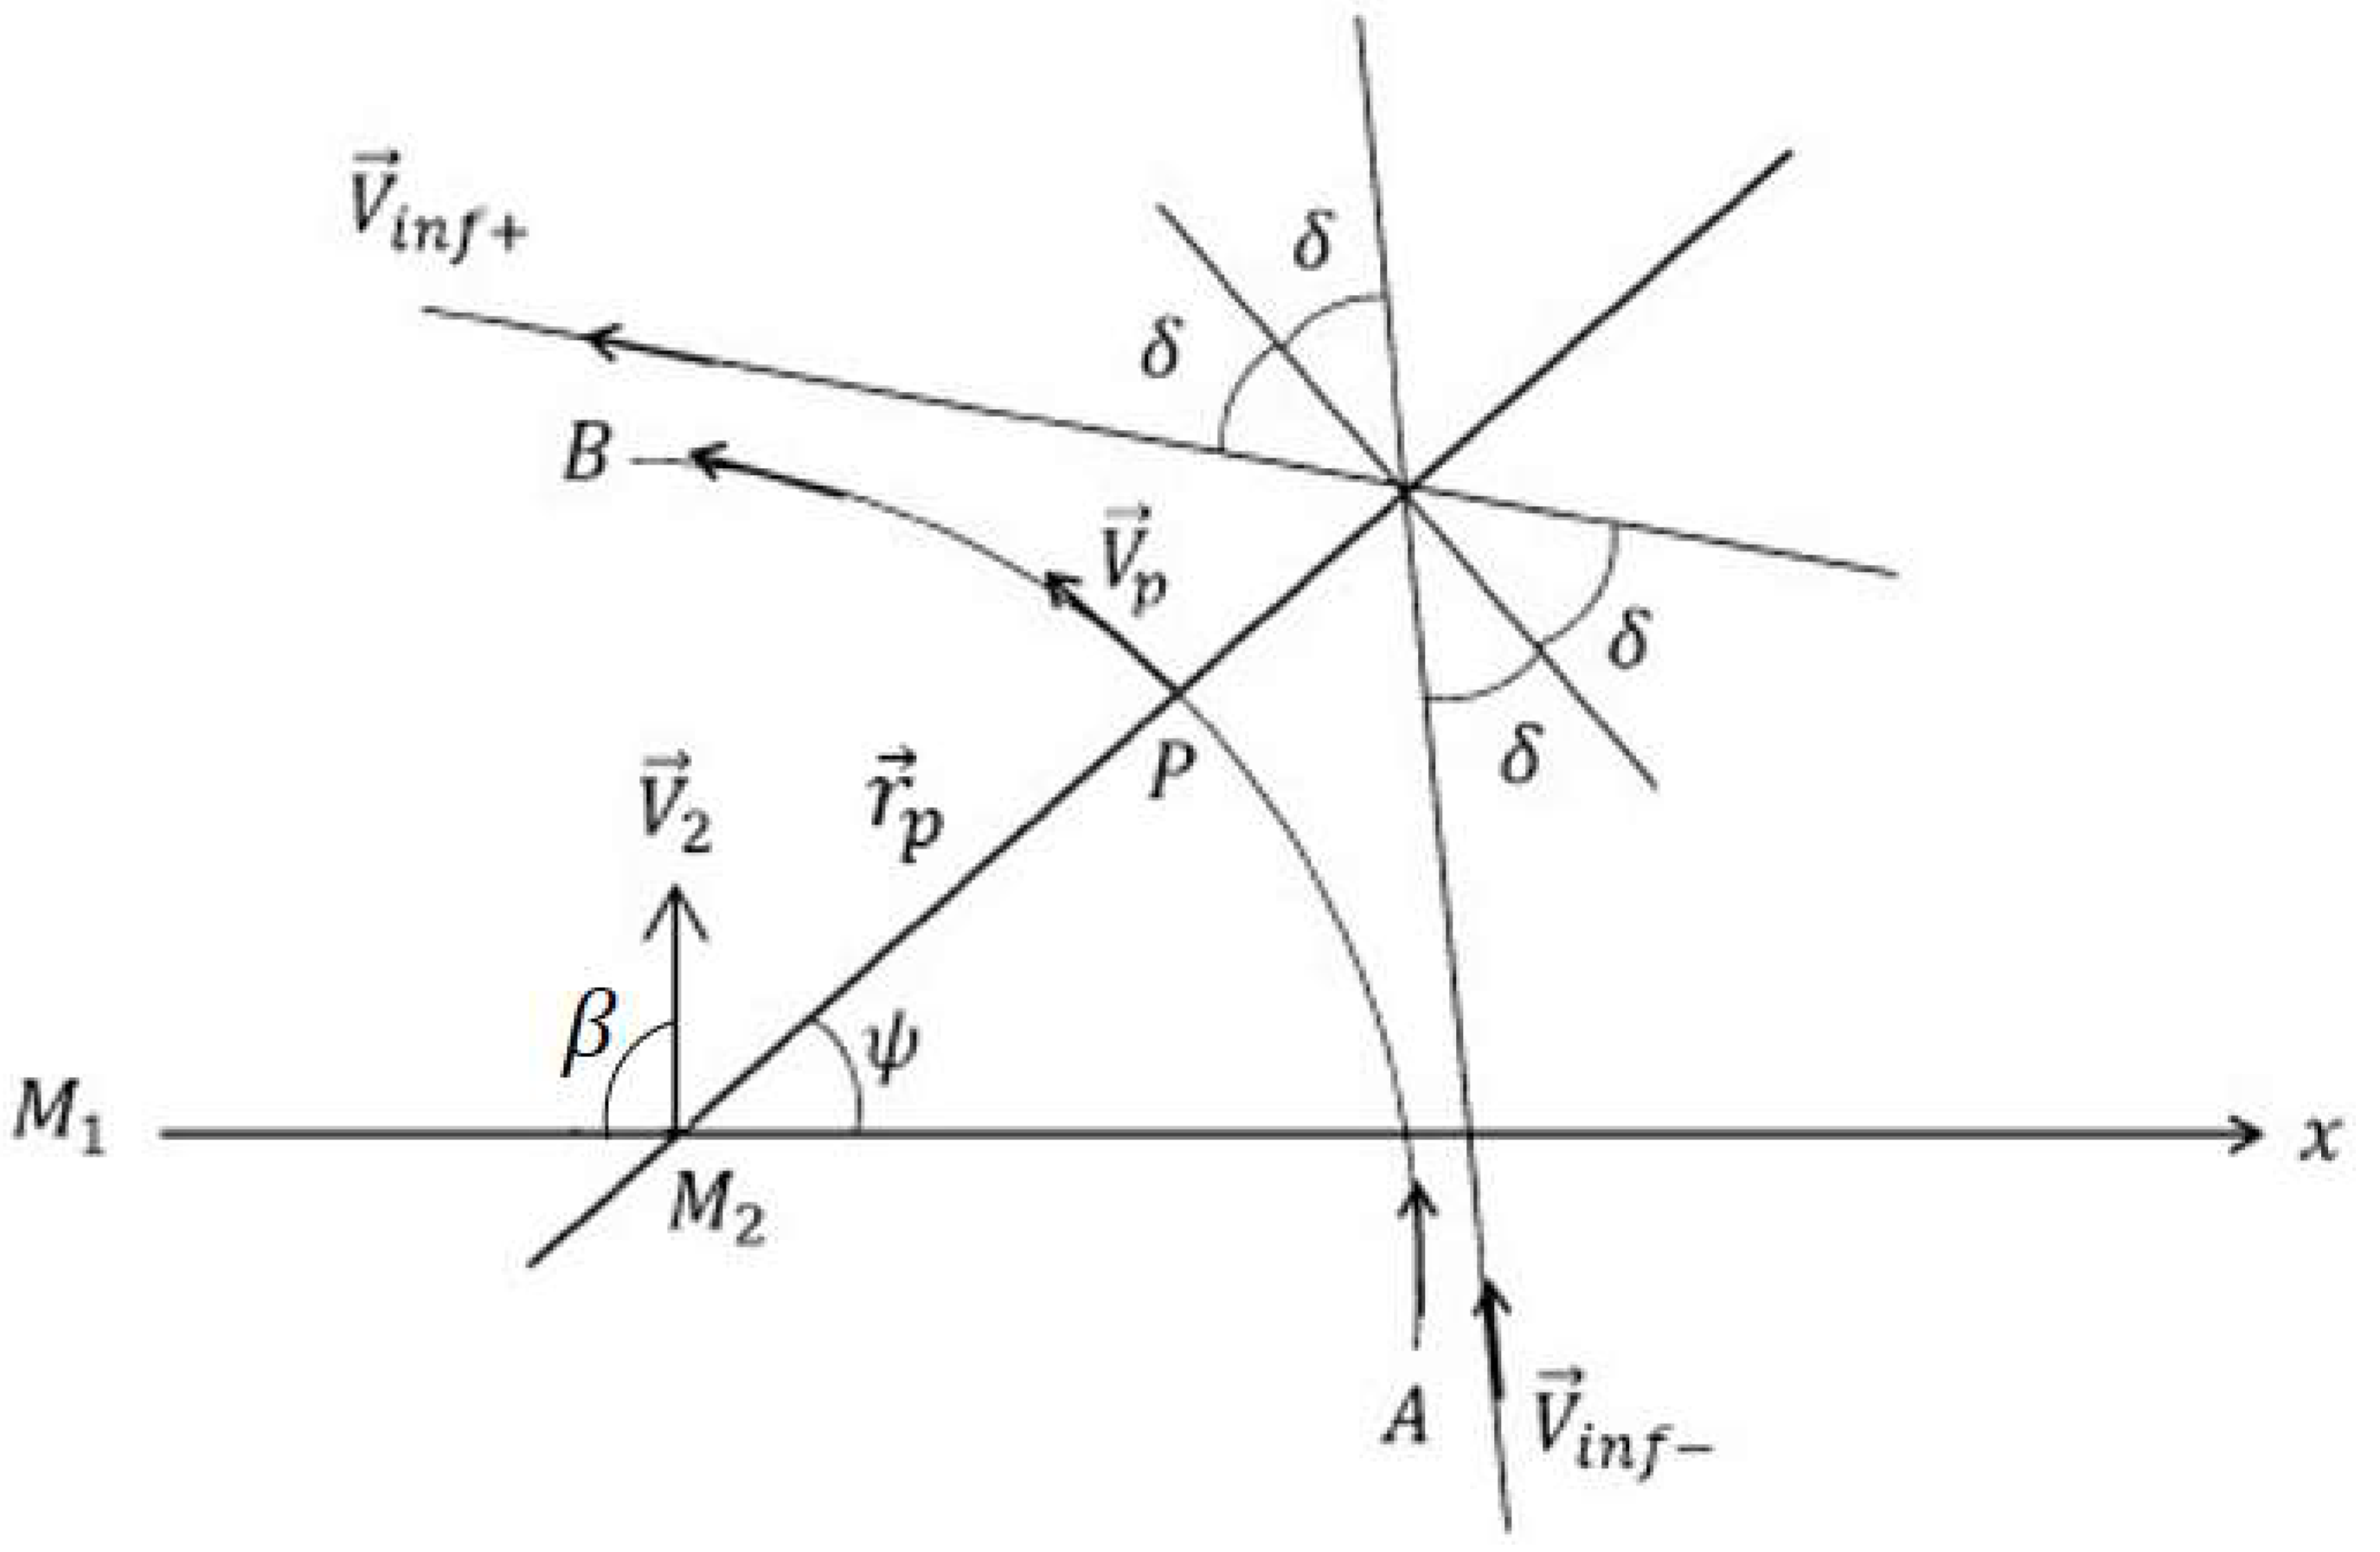


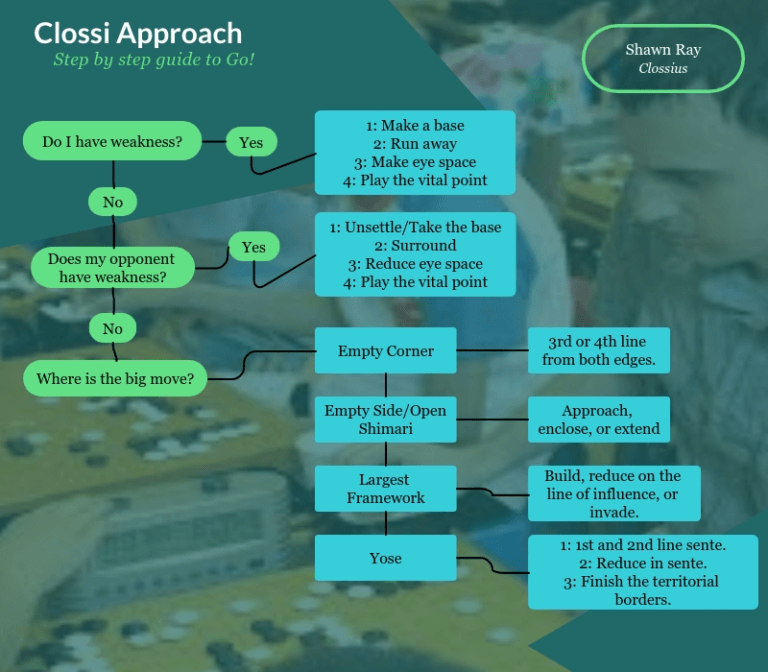


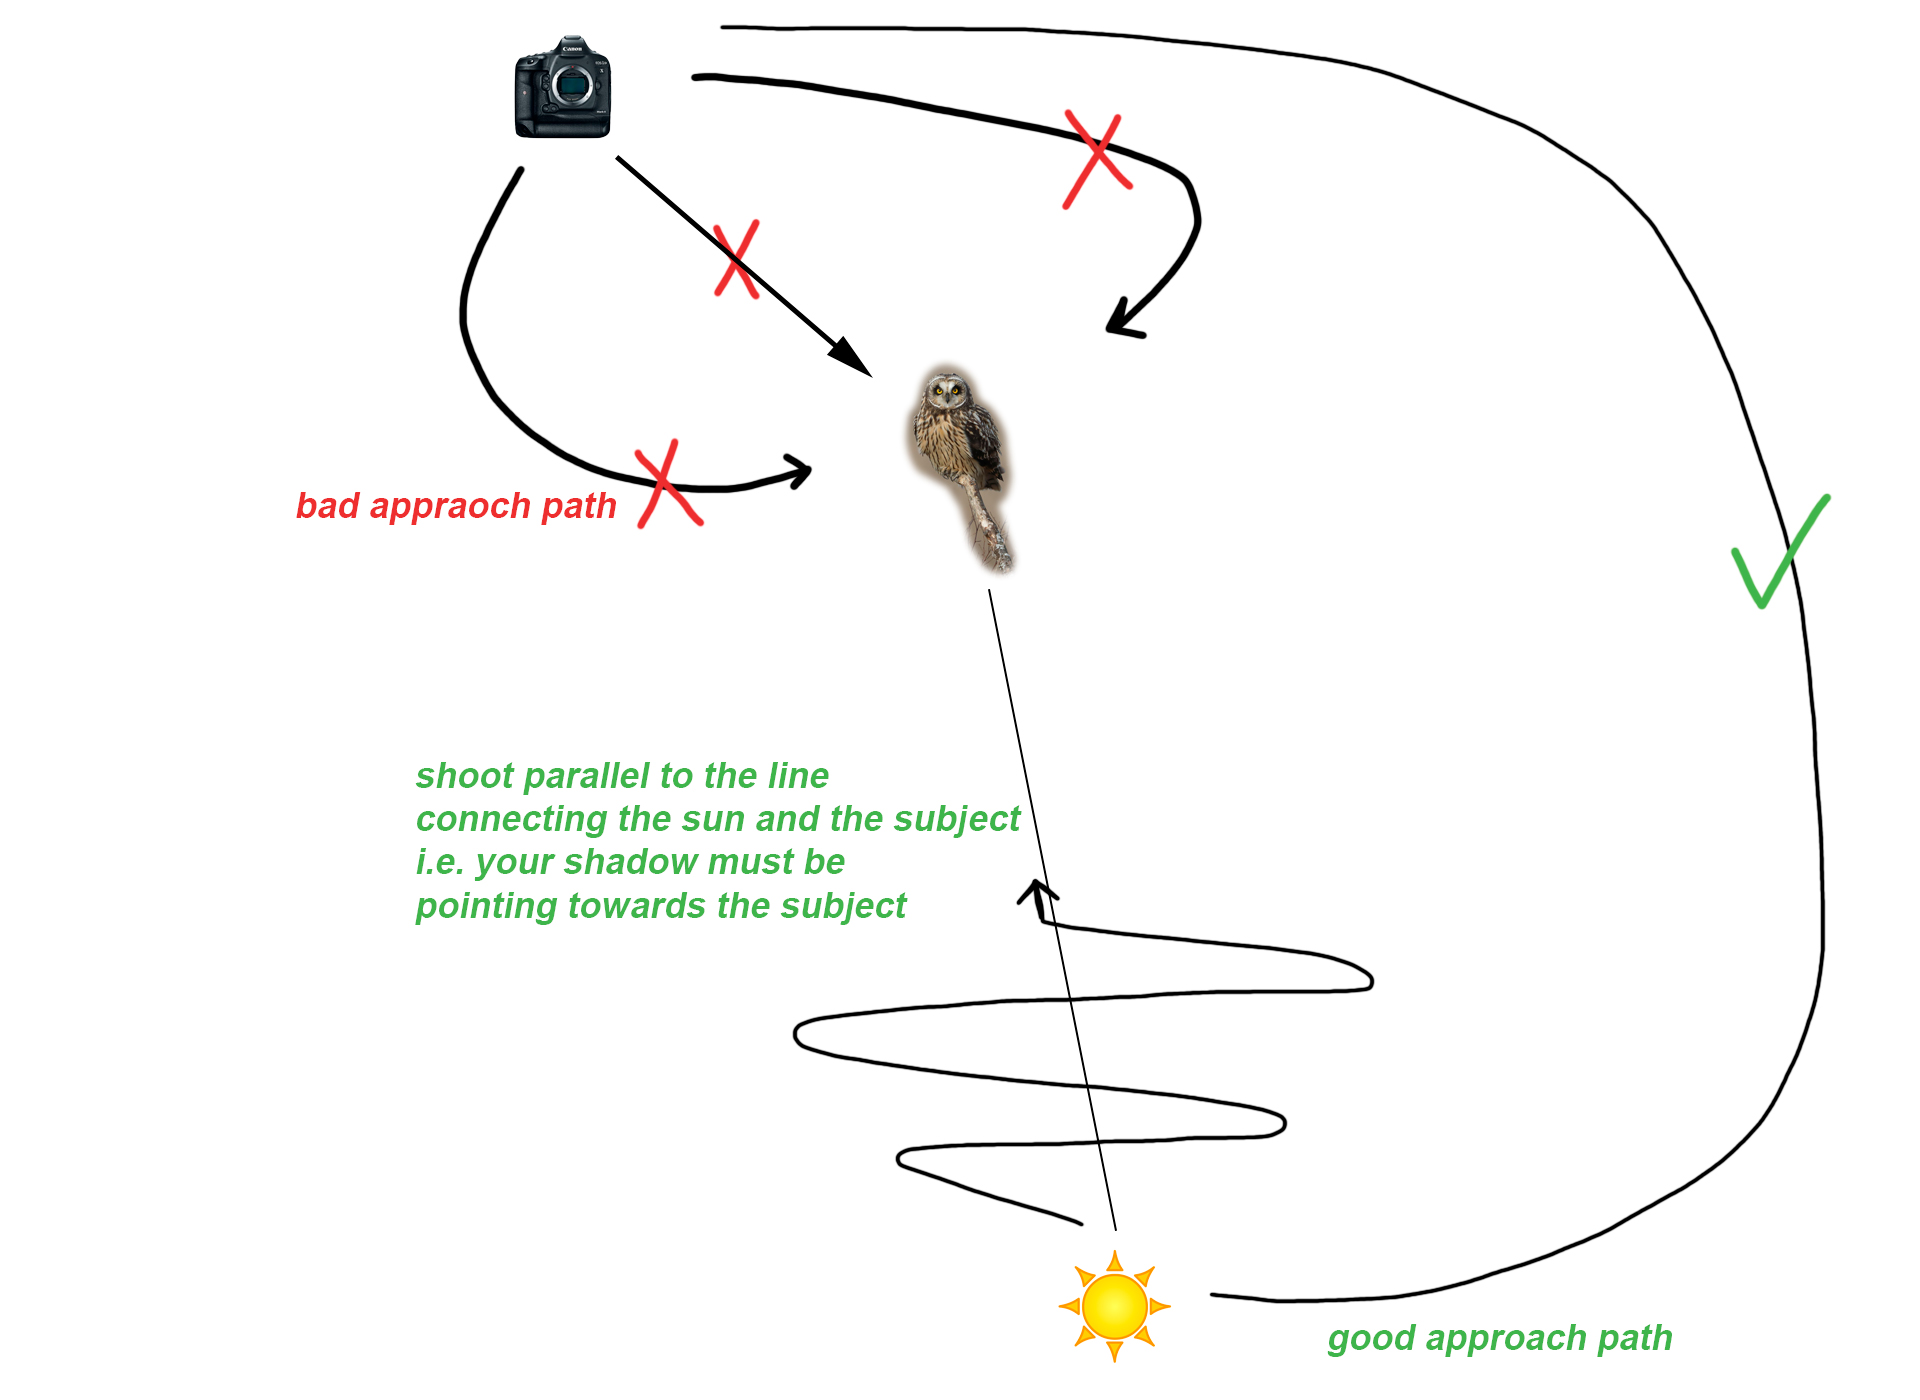


















Preserve history with our stunning historical Approach Move Close collection of substantial collections of heritage images. legacy-honoring highlighting photography, images, and pictures. perfect for historical documentation and education. Each Approach Move Close image is carefully selected for superior visual impact and professional quality. Suitable for various applications including web design, social media, personal projects, and digital content creation All Approach Move Close images are available in high resolution with professional-grade quality, optimized for both digital and print applications, and include comprehensive metadata for easy organization and usage. Our Approach Move Close gallery offers diverse visual resources to bring your ideas to life. Advanced search capabilities make finding the perfect Approach Move Close image effortless and efficient. Reliable customer support ensures smooth experience throughout the Approach Move Close selection process. Comprehensive tagging systems facilitate quick discovery of relevant Approach Move Close content. Whether for commercial projects or personal use, our Approach Move Close collection delivers consistent excellence. Diverse style options within the Approach Move Close collection suit various aesthetic preferences. Time-saving browsing features help users locate ideal Approach Move Close images quickly. Professional licensing options accommodate both commercial and educational usage requirements. Our Approach Move Close database continuously expands with fresh, relevant content from skilled photographers.